Lunar Path Determination
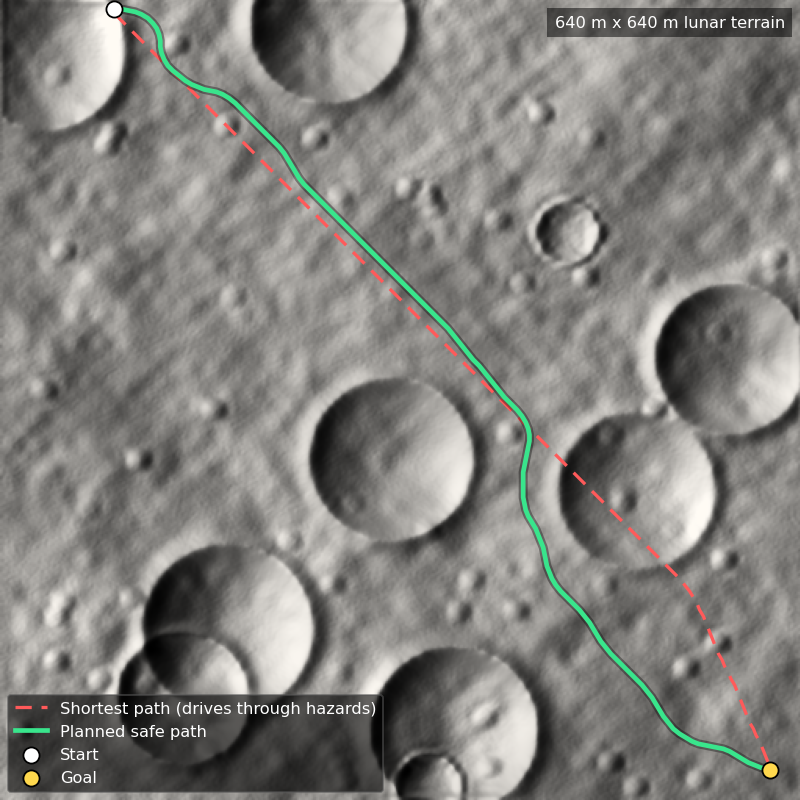
Hazard-aware rover navigation. A fresh lunar terrain is generated in your browser; A* plans the shortest route and a hazard-aware safe route, and both are compared.
Shortest pathSafe pathHazardStart / goal
| Shortest | Safe |
|---|
Browser version: hazard scores here come from slope and roughness rules so it runs instantly. The Python project trains a Random Forest on six terrain features (F1 0.88, ROC-AUC 0.98 on unseen maps). Across 20 test maps the safe planner cut hazards crossed from 29.1 to 0.3 and max slope from 35.4° to 11.9° for 14.9% extra distance.
Result from the Python pipeline (trained model):